Projects & Datasets
My research builds large-scale, real-world datasets and benchmarks for driving automation — lane-keeping assist, human takeovers, control transitions, driver behavior, and safety alerting. Below is the full set of projects. Explore more of my work on Google Scholar, Hugging Face, ResearchGate, and GitHub.
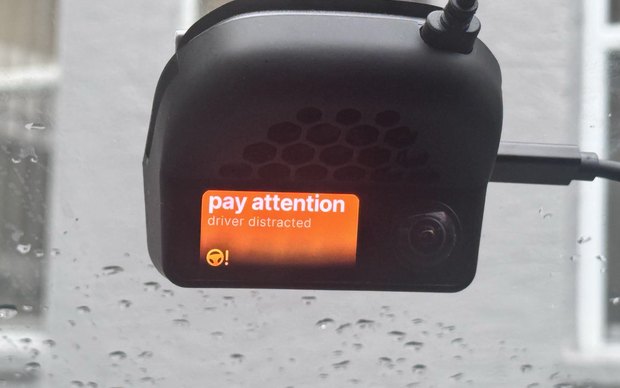
TriDrive
Joint driver, vehicle and road modeling for human-centered driving: a world-model-based driver-monitoring system that forecasts driver kinematics, vehicle dynamics and road demands, deployed in real time on comma four and validated in a 14-participant on-road study.
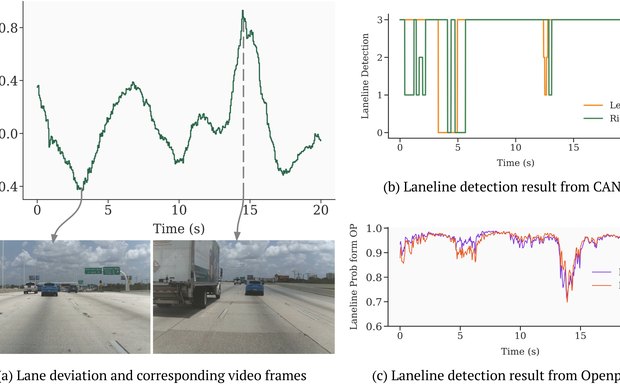
OpenLKA
The first large-scale open dataset of Lane Keeping Assist from 62 production vehicle models under real-world driving, pairing decoded CAN-bus logs (verified decoders for seven makes) with synchronized video.
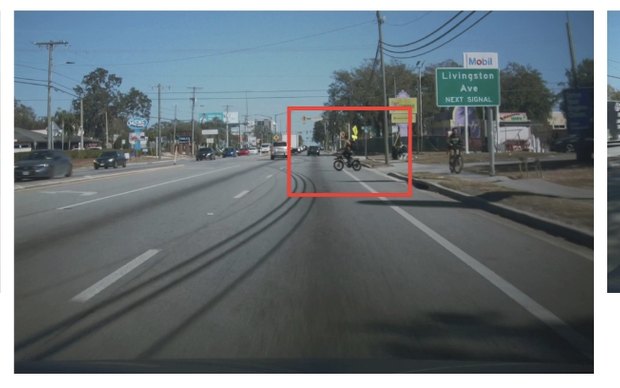
ADAS-TO
15,000+ real-world ADAS takeover events from 327 drivers across 22 brands — multimodal and vision-language-annotated — capturing the moment drivers reclaim control.
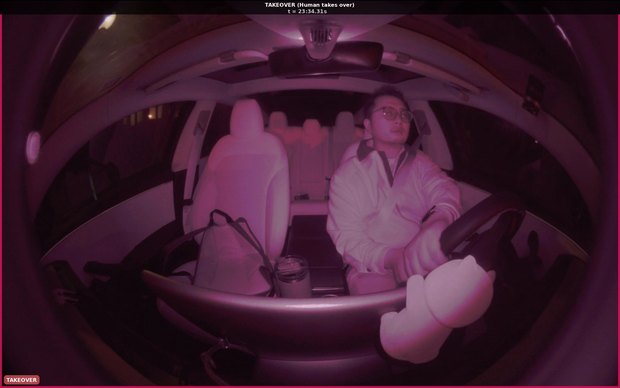
BATON
A multimodal benchmark for bidirectional human–automation control transitions: 781 routes, 173 drivers and 204.9 h of real-world driving-automation use with front and cabin video, CAN, radar and route context; takeover scored as detection (T3-D) and as anticipation (T3-A).
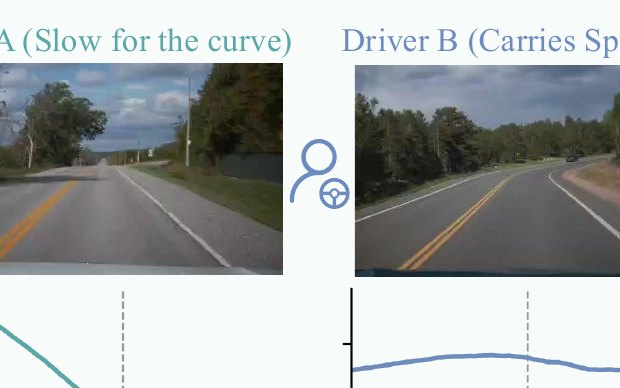
DriveDNA
A benchmark for driving-style identification — 4,121 drives from 465 drivers, 975 h — that isolates driver-specific behavior from vehicle, route and environment confounds.
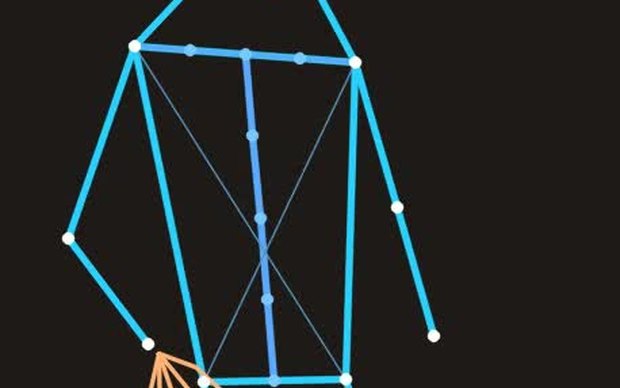
DriveMotion
A multi-source, skeleton-only benchmark for driver motion forecasting: 400 h of in-cabin motion as 133-keypoint skeletons at 10 Hz from 360 drivers (fleet, web, AIDE), anchored on real manoeuvres.
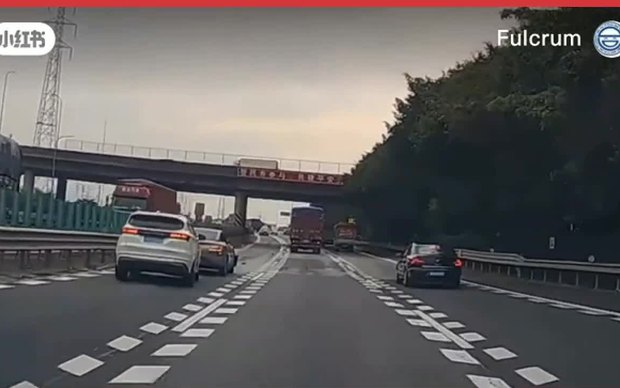
VLAlert
Observe Before You Alert: a vision–language framework for adaptive driver alerting (SILENT / OBSERVE / ALERT), with VLAlert-Bench — 192,892 one-second labeled ticks from six datasets.