PhD Student · University of South Florida · MOTIF-Lab
Yuhang Wang 王雨航
Vision–language models that decide when to alert the driver.
- IEEE/CVF WACV 2027
- CoRL 2026
- IEEE ITSC 2026
- IEEE ITSC 2025
- TRB 2026
- SMI 2024 · Best Paper
- CoRL 2026 · Travel Award
01At a glance
My PhD builds vision–language models, large-scale real-world datasets and benchmarks for safer driving automation.
- 7Projects6 datasets & benchmarks, 1 on-road system
- 6Selected papersWACV 2027 · CoRL 2026 · ITSC 2026 · ITSC 2025 · TRB 2026 · SMI 2024
- 975 hNaturalistic driving in DriveDNA4,121 drives · 465 drivers
- 192,892Labeled ticks in VLAlert-Bench13,534 videos · 6 datasets
- 2Conference awardsBest Paper SMI 2024 · Travel Award CoRL 2026
- Multimodal LearningVideo, CAN, radar & language — fused for driving understanding
- Human-Centered AIAlerting, trust and shared control that drivers accept
- Driver Behavior ModelingTakeovers, driving style and body motion at scale
- Autonomous DrivingSafety of production ADAS & automated vehicles
02Projects
Featured Projects
Six datasets and benchmarks and one on-road system, all built from real drivers, real vehicles and real roads.
All projects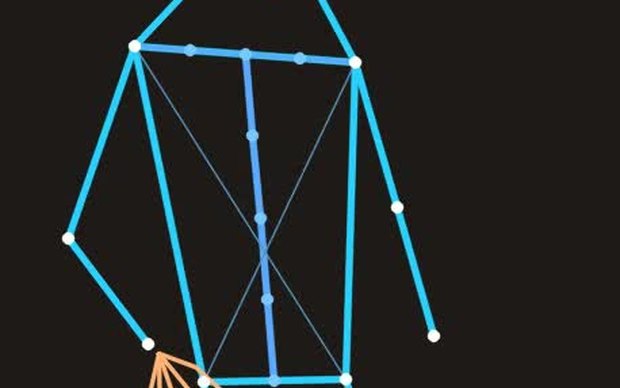
IEEE/CVF WACV 2027
DriveMotion
Driver body-motion forecasting
400 h of in-cabin motion as 133-keypoint skeletons at 10 Hz from 360 drivers — released skeleton-only.
Open project
CoRL 2026 Travel Award
VLAlert
Observe before you alert
Decides when to stay SILENT, OBSERVE or ALERT; VLAlert-Bench: 192,892 labeled ticks from six datasets.
Open project
arXiv 2026 · under review
TriDrive
Joint driver–vehicle–road modeling
Forecasts driver kinematics, vehicle dynamics and road demands in real time on comma four; validated with 14 drivers on the road.
Open project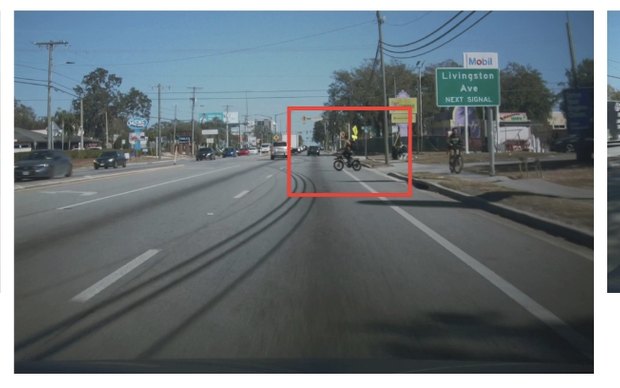
IEEE ITSC 2026
ADAS-TO
Human–ADAS takeover transitions
15,659 real-world ADAS takeover clips from 327 drivers across 22 brands, with vision-language annotations.
Open project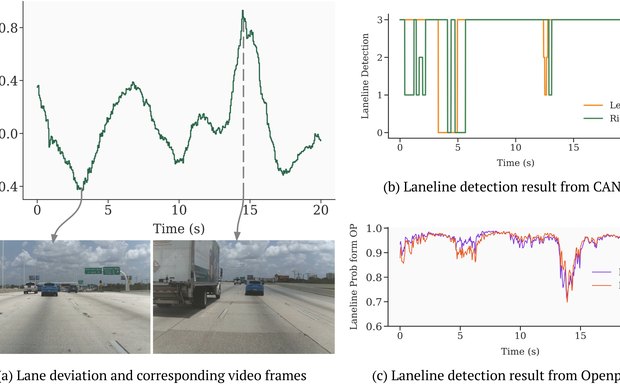
IEEE ITSC 2025
OpenLKA
Lane keeping on real roads
Lane Keeping Assist from 62 production vehicle models — decoded CAN logs paired with synchronized video.
Open project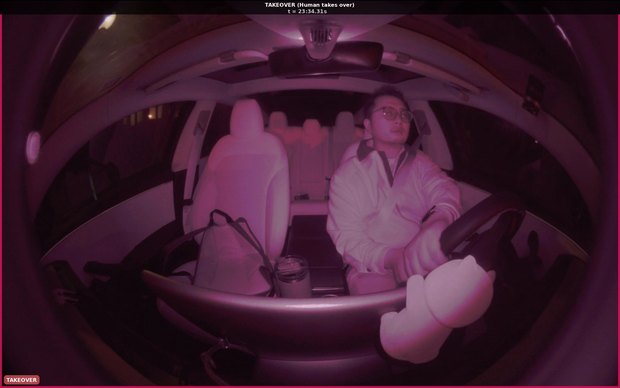
arXiv 2026
BATON
Bidirectional control transitions
781 routes, 173 drivers, 204.9 h of driving-automation use; takeover scored as detection and as anticipation.
Open project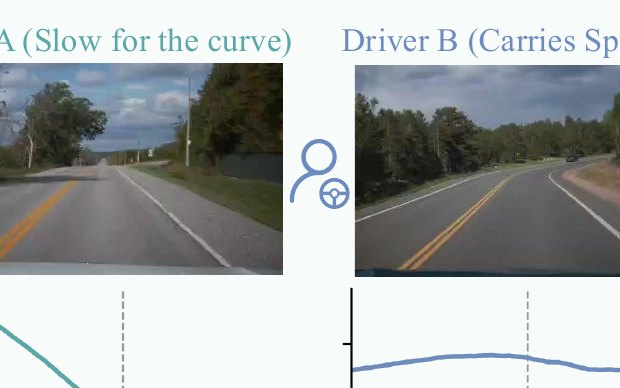
arXiv 2026
DriveDNA
Driving-style identification
4,121 drives from 465 drivers, 975 h — isolating driver-specific behavior from vehicle, route and environment.
Open projectIndex
All projects
Every dataset, benchmark and system — with papers, code and data access in one place.
- DriveMotion WACV 2027
- VLAlert CoRL 2026
- TriDrive arXiv 2026
- ADAS-TO ITSC 2026
- OpenLKA ITSC 2025
- BATON arXiv 2026
- DriveDNA arXiv 2026
03Publications
Selected Publications
Five recent papers, newest first. Preprints and the complete list are on the publications page.
All publications-
WACV 2027
DriveMotion: A Large-Scale Multi-Source Benchmark for Driver Motion Sequence Modeling and Forecasting
IEEE/CVF Winter Conference on Applications of Computer Vision (WACV 2027) · Lake Buena Vista, Florida, United States. January, 2027.
-
CoRL 2026 · Travel Award
Observe Before You Alert: Adaptive Driver Alerting with Vision–Language Models
Conference on Robot Learning (CoRL 2026). CoRL 2026 Travel Award.
-
ITSC 2026
ADAS-TO: A Large-Scale Multimodal Naturalistic Dataset and Empirical Characterization of Human Takeovers during ADAS Engagement
IEEE Intelligent Transportation Systems Conference (ITSC 2026)
-
ITSC 2025
OpenLKA: An Open Dataset of Lane Keeping Assist from Production Vehicles Under Real-World Driving Conditions
IEEE Intelligent Transportation Systems Conference (ITSC 2025) · Gold Coast, Australia. November, 2025. Journal extension under review at Accident Analysis & Prevention.
-
SMI 2024 · Best Paper
Computational design of custom-fit PAP masks
Shape Modeling International (SMI 2024) · Wayne State University, United States. July, 2024.
04News
News & Updates
Acceptances, releases and awards — newest first.
🏆 Awarded a CoRL 2026 Travel Award ($1,000) for Observe Before You Alert at the Conference on Robot Learning. [Awards]
🎉 DriveMotion: A Large-Scale Multi-Source Benchmark for Driver Motion Sequence Modeling and Forecasting is accepted by WACV 2027! See you at Disney Springs, Florida, in January. [arXiv] [Data]
🎉 Seven papers accepted for presentation at the TRB 2027 Annual Meeting — five first-author (CockpitWM, Observe Before You Alert, BATON, Human Takeovers in Level-2 ADAS, DriveDNA) and two co-authored. See you in Washington, D.C.!
🚗 New project page: TriDrive — Joint Driver, Vehicle, and Road Modeling for Human-Centered Driving, a world-model-based driver-monitoring system running in real time on comma four, validated in a 14-participant on-road study. [Explore]
🎉 Observe Before You Alert: Adaptive Driver Alerting with Vision–Language Models is accepted by CoRL 2026! [PDF]
📦 DriveMotion — a multi-source, skeleton-only benchmark for driver motion forecasting (400 h, 360 drivers) — is on arXiv and Hugging Face.
15 earlier updates
🎉 Three papers accepted by ITSC 2026: ADAS-TO, Cut-In Gap Acceptance Toward Autonomous vs. Human-Driven Vehicles, and A Closed-loop, State-centric, Multi-agent Framework for Passenger Load Estimation.
3 papers accepted by TRB Annual Meeting — see you in D.C.!
From OpenLKA to LKAlert abstract accepted by INFORMS 2025 (Intelligent Transportation Systems and Cybersecurity session), Atlanta.
OpenLKA is accepted by ITSC 2025.
Extended abstract accepted by the Second USF Artificial Intelligence + X Symposium (poster).
Computational design of custom-fit PAP masks won the Best Paper award at SMI 2024.
Received a PhD offer from the Civil Engineering department at the University of South Florida!
Computational design of custom-fit PAP masks accepted for presentation at SMI 2024.
Started as a visiting student at SUTD CGL Lab, advised by Prof. Peng Song.
🥈 Silver Medal at CCPC Guilin — Team 廉颇老矣,尚能夺金? · rank 47.
Joined ZelosTech's PnC group as an algorithm engineering intern.
🥇 Gold Medal at the ICPC National Contest — Team Tops dogs like real party · rank 16.
Joined the team supervised by Prof. Xiaolong Xu.
05About
About Me

I am Yuhang Wang (Henry, 王雨航), a PhD student in Civil Engineering Transportation at the University of South Florida, working as a research assistant at the MOTIF-Lab advised by Prof. Hao Zhou. I previously spent a year with Prof. Peng Song at the Singapore University of Technology and Design.
My research applies deep learning and the capabilities of self-driving vehicles to transportation problems — building the large-scale, real-world datasets the field is missing, and pursuing human-centered driving automation that earns drivers' trust. If any of this interests you, I would love to chat and collaborate: yuhangw@usf.edu.
- Aug 2024 – Present
University of South Florida — Transportation PhD student, advised by Prof. Hao Zhou
- Oct 2023 – Jul 2024
Singapore University of Technology and Design — Visiting student, advised by Prof. Peng Song
- Sep 2020 – Jun 2024
Nanjing University of Information Science and Technology — BEng in CS, advised by Prof. Xiaolong Xu